
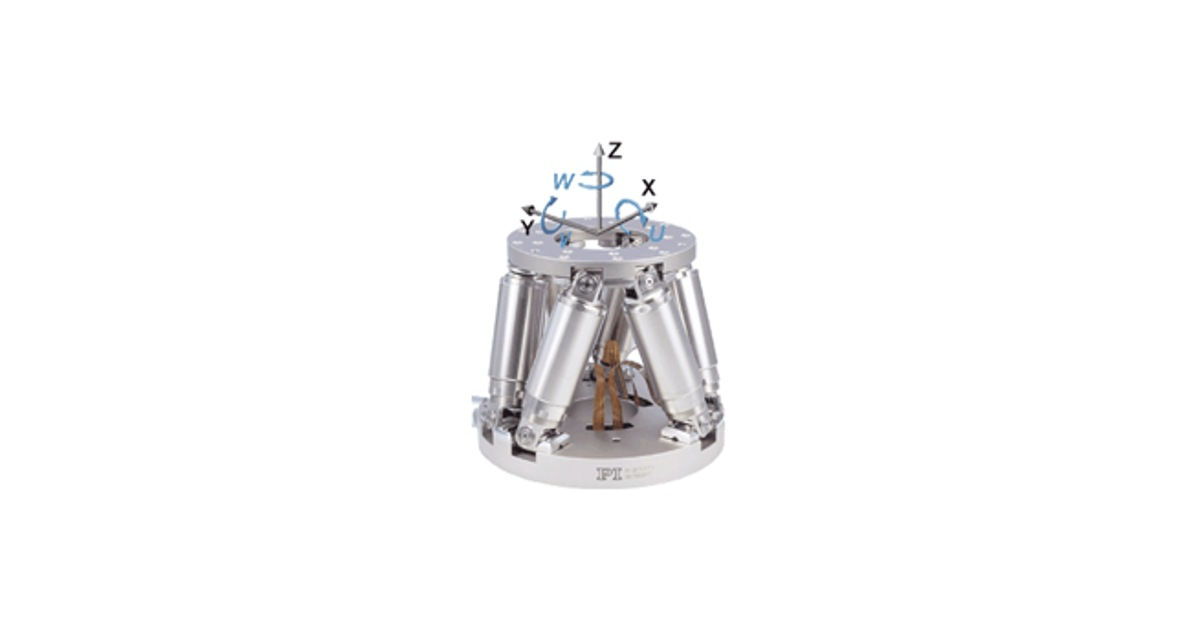
PI H-811 Miniature Hexapods: I2, Hard Stops and Vacuum Variants
PI H-811 Miniature Hexapods: I2, Hard Stops and Vacuum Variants
PI H-811 combines six-axis parallel motion in a compact positioning platform. Current I2 and I2HS data list ±17 mm X, ±16 mm Y and ±6.5 mm Z travel, with rotations depending on axis. I2HS adds external hard stops; vacuum, high-speed and high-resolution versions have distinct identities and must not be assembled into one imaginary maximum-performance unit.
Review Summary
Consider H-811 for photonic alignment and compact precision assembly where six coordinated motions are valuable. Resolve the exact variant, payload orientation and pivot geometry first. The current I2’s 20 mm/s maximum and 5 kg horizontal payload should not be replaced by a historic 25 mm/s family statement.
I2 / I2HS translations X ±17 mm; Y ±16 mm; Z ±6.5 mm; coupled workspace I2 / I2HS rotations θX/θY ±10°; θZ ±21° at specified reference conditions I2 payload 5 kg with horizontal base; 2.5 kg in any orientation I2 speed 20 mm/s maximum; 10 mm/s recommended linear velocity I2 typical repeatability X/Y ±0.15 µm; Z ±0.06 µm unidirectional I2HS distinction External hard stops; not a generic software limit Other variants Vacuum/high-speed/high-resolution configurations require separate data Applications and Industries
Photonics alignment, micromanufacturing and compact six-axis precision assembly.
Industrial automation
Request a quote for the exact configuration,quantity and delivery schedule.
| I2 / I2HS translations | X ±17 mm; Y ±16 mm; Z ±6.5 mm; coupled workspace |
| I2 / I2HS rotations | θX/θY ±10°; θZ ±21° at specified reference conditions |
| I2 payload | 5 kg with horizontal base; 2.5 kg in any orientation |
| I2 speed | 20 mm/s maximum; 10 mm/s recommended linear velocity |
| I2 typical repeatability | X/Y ±0.15 µm; Z ±0.06 µm unidirectional |
| I2HS distinction | External hard stops; not a generic software limit |
| Other variants | Vacuum/high-speed/high-resolution configurations require separate data |


