
DENSO HM-4085 vs Epson GX8-B451: Robot Comparison

Updated: 1 hour ago
IN A NUTSHELL
🔎 THE KEY DIFFERENCE DENSO HM-4085 has the higher stated load capacity and longer stated reach. Those figures help shortlist it for heavier loads or wider layouts, but do not prove a faster production cycle. |
→ CONSIDER DENSO HM-4085 Consider it when additional load capacity and reach matter. This article compares 10 kg and a 850 mm stated reach; include the gripper and part in the load. |
→ CONSIDER Epson GX8-B451 Consider it when its stated load and reach already cover your task and its controls fit your equipment. This article compares 8 kg and a 450 mm stated reach; include the gripper and part in the load. |
💡 THE TAKEAWAY For repetitive pick-and-place or assembly, check the actual vertical stroke and tool rotation as well as horizontal reach. Compare the same loaded cycle and installed quotation before deciding. |

DENSO HM-4085 vs Epson GX8-B451 is a choice about SCARA assembly and planar handling. DENSO HM-4085 and Epson GX8-B451 differ in their working envelope, loading assumptions and engineering ecosystem. A useful decision starts with the exact mechanism and process, then checks whether either robot can execute the required path with the real tool attached. This comparison separates documented specifications from application-level engineering judgments.
DENSO HM-4085 vs Epson GX8-B451: quick verdict
Shortlist DENSO HM-4085 for 10 kg planar handling within the selected 850 mm SCARA envelope. Shortlist Epson GX8-B451 for 8 kg planar handling within the selected 450 mm SCARA envelope. Both are four-axis SCARA candidates, so the decisive questions are planar access, vertical stroke, spindle inertia and the complete assembly cycle. Neither supplies independent tool pitch and roll.
The numerical comparison below uses DENSO HM-4085 against Epson GX8-B451. The stated model scope matters when comparing later revisions or differently equipped installations. Published repeatability describes return to a taught position under specified conditions; it does not establish complete-cell accuracy or prove a faster production cycle.
Specifications and exact configuration scope
Criterion | DENSO HM-4085 | Epson GX8-B451 |
|---|---|---|
Comparison configuration | DENSO HM-4085 | Epson GX8-B451 |
Payload used for comparison | 10 kg | 8 kg |
Reach / motion-area reference | 850 mm | 450 mm |
Axes | 4 | 4 |
Repeatability for this scope | ±0.025 mm | ±0.015 mm |
Controller reference | Confirm offered DENSO controller | Epson RC700-E |
Purchase-price basis | Configuration-specific quotation | Configuration-specific quotation |
Purchase pricing | From $32,000 (arm list price) | From $14,000 (arm list price) |
Read the reach row together with the geometric notes below. Manufacturers may specify an arm-link sum, a wrist-centre motion area or reach to the flange; those dimensions are not interchangeable. The table does not establish access to every point at every tool angle. Controller references identify reviewed packages, and actual compatibility must be confirmed by model, software version and region.
DENSO HM-4085: design and configuration
The DENSO HM-4085 is a 4-axis SCARA robot with a 10 kg payload, an 850 mm arm length and ±0.025 mm repeatability. It is built for high-speed assembly, pick-and-place and palletizing of heavier parts over a wide work area, with a standard cycle time of 0.31 s and a maximum composite speed of 11,450 mm/s. Z-axis strokes from 100 to 400 mm are offered. The robot weighs 53 to 56 kg and is floor mounted. The HM-40 model has a 10 kg maximum; the related HM-4A high-payload version is a different robot and must not lend its 20 kg rating to this model. Select the vertical-stroke suffix and standard or protected configuration explicitly. XY, vertical and rotational repeatability are separate specifications. The current manufacturer standard-model table gives ±0.02 mm for combined J1/J2 positioning; the older ATC review lists ±0.025 mm. This comparison identifies the current table scope explicitly and requires matching the offered generation.
Epson GX8-B451: design and configuration
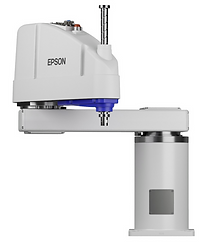
The Epson GX8-B451 is a four-axis SCARA with a 8 kg maximum payload and 450 mm horizontal arm length. The reviewed XY repeatability is ±0.015 mm; Z and rotational repeatability are separate specifications. This comparison retains its exact arm length and generation instead of borrowing another family member’s reach. The reviewed control package is Epson RC700-E. Check vertical stroke, spindle inertia, mounting orientation and protection options on the full order code. A cycle-time headline is not a guarantee at maximum payload or with a wide gripper.
For this pair, Epson GX8-B451 offers 8 kg over the stated 450 mm reference, compared with 10 kg and 850 mm for DENSO HM-4085 example. DENSO HM-4085 has the larger stated distance by 400 mm, but this difference is only a preliminary layout indicator because reference points and joint envelopes can differ. Locate the actual fixture in each manufacturer model before treating this as usable extra working space.
Payload, tooling and a worked load example
Consider an illustrative total wrist load of 6.4 kg: a 1.6 kg tool and adapter package carrying a 4.8 kg part or product group. This arithmetic leaves 3.6 kg below the DENSO HM-4085 example’s nominal limit and 1.6 kg below Epson GX8-B451’s nominal limit. These are mass differences, not safety factors or a validated load approval. A heavy camera, valve block or retained material must be included before recalculating the total.
The example exposes the practical question: is the application limited by mass, by tool offset or by wrist rotation? Epson GX8-B451 is the lower-or-equal nominal payload choice in this pair. DENSO HM-4085 offers more or equal headline mass capacity, but that alone cannot approve an eccentric fixture. Moving the same mass farther from the flange increases the moment, and spreading it increases rotational inertia. Manufacturer load diagrams and the actual centre of gravity govern the final allowable motion.
For the two SCARA configurations, model the tool inertia around the vertical spindle as well as total carried mass. A broad multi-part gripper can satisfy the mass limit while exceeding permitted rotational inertia. Set the controller load and inertia parameters for empty and loaded states, then check insertion stroke and any allowable vertical pressing force separately. Nominal cycle figures do not establish performance at maximum payload.
Reach, orientation and fixture access
Build the same cell model for both candidates: base height, machine opening, fixture datum, maximum part size, tool extension and access for maintenance. DENSO HM-4085 provides a stated 850 mm reference, while Epson GX8-B451 provides 450 mm. Check the deepest production pose and the return path with the loaded tool. An arm that just touches the target at full extension may have little freedom left to turn, retract or avoid a door.
For SCARA assembly, check the full XY sweep, inner dead zone and Z stroke. A horizontal reach figure does not establish that the spindle can descend into the fixture without the tool body or cable loop colliding. Vertical pressing force is a separate limit from payload. Validate screwdriving or insertion forces, spindle inertia and settling with the real fixture. Neither robot gains six-axis pitch and roll freedom merely by having enough horizontal reach.
SCARA motion and assembly fit
The selected DENSO HM-4085 and Epson GX8-B451 should be assessed on the same horizontal transfer, vertical insertion and rotation sequence. Smaller horizontal reach can support a compact bench; larger reach can serve more nests, but also changes the swept area and cable clearance. Check actual Z stroke and tool length against the lowest station and tallest obstruction. Compare XY repeatability with XY repeatability, while keeping Z and rotational values in their own units.
SCARA requirement | DENSO HM-4085 | Epson GX8-B451 |
|---|---|---|
Horizontal scope | 850 mm selected example | 450 mm selected example |
Payload scope | 10 kg maximum for the named configuration | 8 kg maximum for the named configuration |
Z stroke and downforce | Confirm exact spindle and stroke option | Confirm exact spindle and stroke option |
Tool pitch and roll | No independent six-axis pitch/roll | No independent six-axis pitch/roll |
Acceptance path | Same transfer, insert, rotate and settle sequence | Same transfer, insert, rotate and settle sequence |
Precision and throughput: compare the same task
The comparison uses ±0.025 mm for DENSO HM-4085 and ±0.015 mm for Epson GX8-B451. These figures should be read in their documented configuration scope. Repeatability is not absolute accuracy, camera calibration accuracy or finished-part capability. Fixture variation, TCP calibration, thermal conditions and tool compliance can dominate the error at the process point, especially when the tool extends far from the flange.
Ask each integrator to execute the same representative path with the same payload model, tool length, process dwell and stop conditions. Report transfer time, settling time, process time and waiting time separately. Published standard cycles often use different loads and distances; dividing one catalogue cycle by another would not establish the production advantage of DENSO HM-4085 over Epson GX8-B451. Use a measured or validated application cycle before assigning a throughput benefit.
Programming, controls and production integration
DENSO HM-4085 is paired here with Confirm offered DENSO controller, while Epson GX8-B451 uses Epson RC700-E. Controller names identify the review baseline rather than a guarantee that all interface options are included. Compare the actual software revision, teaching workflow, diagnostic tools, fieldbus licences and recovery procedures. An existing trained team and reusable production code may outweigh a small dimensional advantage. Obtain a demonstration of the same machine handshake and interrupted-cycle recovery on both platforms.
Specify the PLC handshakes before ordering: cycle request, ready, busy, complete, fault, part present and recovery authorization. Define how an interrupted operation resumes without repeating a dangerous or quality-critical action. Vision, force sensing, fieldbus communication and external-axis coordination must be checked as explicit included or optional functions. An Ethernet connector does not by itself prove that a particular industrial protocol or software interface is licensed and supported.
Protection, installation and maintenance
Match the precise protection package to the process. Standard, protected, cleanroom, foundry and washing configurations can have different seals, services and maintenance requirements. Do not transfer the best optional IP or cleanroom rating to an unprotected base model. Check the controller location, cable bend radius, available lifting access and base reactions with the installer.
Treat safe operation as a property of the complete task and installation. Include the tool, sharp workpiece edges, trapping points, dropped loads and machine access. These industrial robots require task-specific safeguarding; payload or compact size does not establish safe unguarded operation. Plan tool replacement and fault recovery without dismantling the whole installation, and include connector access, lubrication and spare-cable replacement in the maintenance layout.
Price and lifecycle value
Published arm list prices: DENSO HM-4085 is listed from $32,000 and Epson GX8-B451 is listed from $14,000. Request configuration-specific quotations for DENSO HM-4085 and Epson GX8-B451. An arm-only number is not the price of a commissioned production cell. Ask for separate line items for controller, pendant, communication options, end effector, safety equipment, installation, acceptance, training and warranty. Price changes, regional support and included software can reverse an apparent hardware-cost advantage. Compare the same delivered scope before calculating payback.
Compare the installed production scope: tool, fixtures, sensing, guarding, machine interface, programming, acceptance and training. For small-parts automation, include feeders, vision calibration, nests and rejected-part handling. Keep purchase cost and recurring support costs separate. No payback figure is defensible until the actual cycle, yield, utilization and installation quotation are known.
Selection and acceptance plan
Decision gate | DENSO HM-4085 | Epson GX8-B451 |
|---|---|---|
Strongest documented fit | 10 kg planar handling within the selected 850 mm SCARA envelope | 8 kg planar handling within the selected 450 mm SCARA envelope |
Main boundary | Tool mass, wrist moments and access constrain the headline specification. | Four axes do not provide arbitrary wrist pitch and roll. |
Required approval | Exact DENSO variant, tool load and validated process path | Exact competitor revision, tool load and validated process path |
Acceptance evidence | Agreed parts, path, quality and recovery results | The same agreed parts, path, quality and recovery results |
Advance DENSO HM-4085 when 10 kg planar handling within the selected 850 mm SCARA envelope solves the real constraint and its selected configuration passes the load and access checks. Advance Epson GX8-B451 when 8 kg planar handling within the selected 450 mm SCARA envelope provides the more suitable process arrangement. Reject either candidate if a mandatory pose, protection requirement or controller function cannot be demonstrated. A purchasing shortlist should preserve these conditions instead of converting a single catalogue advantage into a blanket recommendation.
Before acceptance, agree the representative parts, tool states, operating sequence and quality criteria with both suppliers. Demonstrate cold start, normal production, rejected parts, interrupted cycles and controlled recovery. Record the final tool data and software backup. This turns the comparison into a repeatable purchasing decision and helps prevent a later fixture change from invalidating the original robot selection.
Motion architecture and functionality
DENSO HM-4085 has 4 axes and Epson GX8-B451 has 4 axes. Both SCARA mechanisms combine horizontal positioning, vertical travel and rotation about the tool axis. Their stiff vertical-axis architecture can suit insertion and assembly, but it does not provide independent tool pitch and roll. Check gripping, part detection, optional vision and the machine handshake as separate functions. Confirm the delivered I/O and licensed protocols; an available option is not necessarily included hardware.
Industries and application fit
For DENSO HM-4085 vs Epson GX8-B451, use the actual part and process as the industry filter. Electronics assembly, component packaging and small mechanical assembly are plausible candidates when the required movement is primarily horizontal transfer plus vertical insertion. These are application-selection judgments, not claims that either exact model is installed at a named customer. A food, medical-device or clean-production application additionally requires the correct material, lubrication and protection package; the base model name does not establish hygienic or cleanroom compliance.
Selection issue | DENSO HM-4085 | Epson GX8-B451 |
|---|---|---|
Tool and workpiece mass | 10 kg named scope; include the complete tool | 8 kg named scope; include the complete tool |
Working reference | 850 mm | 450 mm |
Main configuration boundary | Tool mass, wrist moments and access constrain the headline specification. | Four axes do not provide arbitrary wrist pitch and roll. |
Process approval | Demonstrate the actual loaded path and recovery | Demonstrate the same loaded path and recovery |
Frequently asked questions
Which robot is better for this application?
DENSO HM-4085 is the stronger starting point for 10 kg planar handling within the selected 850 mm SCARA envelope, while Epson GX8-B451 is worth shortlisting for 8 kg planar handling within the selected 450 mm SCARA envelope. The final choice depends on the real loaded path, required protection, controls and acceptance results. Neither a higher payload nor a longer reach establishes a universal winner.
What payload should I use for the comparison?
Use 10 kg for the specified DENSO HM-4085 example and 8 kg for Epson GX8-B451, subject to all documented load and orientation conditions. Include the tool, adapters, sensors and carried part. Four axes do not provide arbitrary wrist pitch and roll.
Does the stated reach guarantee access to my fixture?
No. The comparison gives 850 mm for DENSO HM-4085 and 450 mm for Epson GX8-B451 using the stated model references. Joint limits, reach reference points, wrist orientation, tool length and collisions determine whether the actual fixture is accessible. Simulate the full approach and exit path.
Can I use the best specifications from every family variant?
No. Keep each named model and revision intact. A different arm length, controller generation or protection option can change the relevant specification. Do not combine one version’s maximum payload with another version’s maximum reach.
Is repeatability the same as finished-part accuracy?
No. The stated values are ±0.025 mm for DENSO HM-4085 scope and ±0.015 mm for the competitor scope. Finished-part results also depend on fixtures, TCP calibration, sensing, thermal conditions and tool compliance. Validate the actual process instead of treating catalogue repeatability as a complete accuracy guarantee.
How should purchase prices be compared?
Use current written quotations for DENSO HM-4085 and Epson GX8-B451 with the same arm, controller, software, tooling and commissioning scope. This comparison does not represent an ATC sales offer or stock confirmation. Historical review figures are not a substitute for a configuration-specific purchase quotation.
Can these robots operate safely next to people without guarding?
These specifications do not establish a safe unguarded installation. Assess the complete task, tool, load and machine interface, then implement and validate the required safeguarding and operating procedures. Do not infer collaborative operation from a compact arm, limited payload or education setting.
What should an acceptance test compare?
Use the same parts, actual tool load, fixture locations, path and quality criteria for DENSO HM-4085 and Epson GX8-B451. Check production timing, settling, interruptions and recovery. Include the most difficult loaded approach and retreat. Approve the exact delivered configuration and preserve its final settings.
Related ATC reviews
Specifications describe the model scope identified above. Purchase pricing requires a current configuration-specific quotation. Confirm current manufacturer documentation, local supply, controller compatibility and the exact configuration before purchase.


