
ABB IRB 760 vs Kawasaki MX500N: Robot Comparison

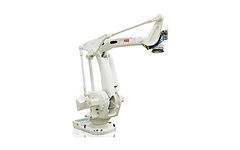
ABB IRB 760 vs Kawasaki MX500N is a choice about palletizing and load orientation. ABB IRB 760 and Kawasaki MX500N differ in their working envelope, loading assumptions and engineering ecosystem. A useful decision starts with the exact mechanism and process, then checks whether either robot can execute the required path with the real tool attached. This comparison separates documented specifications from application-level engineering judgments.
ABB IRB 760 vs Kawasaki MX500N: quick verdict
Shortlist ABB IRB 760 for level-load palletizing with the specified ABB payload. Shortlist Kawasaki MX500N for heavy-load reorientation using a six-axis wrist. First decide whether the product stays level or must be tilted. A payload match does not remove an architectural difference between four and six axes.
The numerical comparison below uses ABB IRB 760 against Kawasaki MX500N. The stated model scope matters when comparing later revisions or differently equipped installations. Published repeatability describes return to a taught position under specified conditions; it does not establish complete-cell accuracy or prove a faster production cycle.
Specifications and exact configuration scope
Criterion | ABB IRB 760 | Kawasaki MX500N |
|---|---|---|
Comparison configuration | ABB IRB 760 | Kawasaki MX500N |
Maximum wrist payload | 450 kg | 500 kg |
Reach / motion-area reference | 3180 mm | 2540 mm |
Axes | 4 | 6 |
Repeatability for this scope | ±0.05 mm | ±0.5 mm |
Controller reference | ABB IRC5 or OmniCore | Confirm offered Kawasaki controller |
Historical ATC review starting reference | From USD 90,000 | From USD 100,000 |
Purchase pricing | Request a configuration-specific quote | Request a configuration-specific quote |
Read the reach row together with the geometric notes below. Manufacturers may specify an arm-link sum, a wrist-centre motion area or reach to the flange; those dimensions are not interchangeable. The table does not establish access to every point at every tool angle. Controller references identify reviewed packages, and actual compatibility must be confirmed by model, software version and region.
ABB IRB 760: design and configuration
The IRB 760 is a four-axis, 450 kg palletizing robot with 3180 mm reach. It is relevant to heavy groups and full-layer transfers while keeping the load level. Layer-gripper mass and the changing centre of gravity of a partially retained layer are central to selection; gross payload alone does not establish suitability.

Kawasaki MX500N: design and configuration
The reviewed MX500N is a six-axis, 500 kg robot with 2540 mm reach and a legacy ±0.5 mm repeatability reference. Confirm revision-specific data and controller compatibility before procurement. The six-axis wrist can address load orientation tasks that a four-axis palletizer cannot perform directly, at the cost of a different path and cell layout.
For this pair, Kawasaki MX500N offers 500 kg over the stated 2540 mm reference, compared with 450 kg and 3180 mm for the ABB example. ABB IRB 760 has the larger stated distance by 640 mm, but this difference is only a preliminary layout indicator because reference points and joint envelopes can differ. Locate the actual fixture in each manufacturer model before treating this as usable extra working space.
Payload, tooling and a worked load example
Consider an illustrative total wrist load of 360 kg: a 90 kg tool and adapter package carrying a 270 kg part or product group. This arithmetic leaves 90 kg below the ABB IRB 760 example’s nominal limit and 140 kg below Kawasaki MX500N’s nominal limit. These are mass differences, not safety factors or a validated load approval. A heavy camera, valve block or retained material must be included before recalculating the total.
The example exposes the practical question: is the application limited by mass, by tool offset or by wrist rotation? ABB IRB 760 is the lower-or-equal nominal payload choice in this pair. Kawasaki MX500N offers more or equal headline mass capacity, but that alone cannot approve an eccentric fixture. Moving the same mass farther from the flange increases the moment, and spreading it increases rotational inertia. Manufacturer load diagrams and the actual centre of gravity govern the final allowable motion.
Model the empty, partly loaded and fully loaded tool states separately. A vacuum layer gripper, a weld torch with hoses or an inspection head may change its effective loading during the cycle. Set the controller’s load data for each supported state and validate the transition logic. A payload table cannot predict acceleration derating, cable pull or transient reactions at a machine interface.
Reach, orientation and fixture access
Build the same cell model for both candidates: base height, machine opening, fixture datum, maximum part size, tool extension and access for maintenance. ABB IRB 760 provides a stated 3180 mm reference, while Kawasaki MX500N provides 2540 mm. Check the deepest production pose and the return path with the loaded tool. An arm that just touches the target at full extension may have little freedom left to turn, retract or avoid a door.
For this comparison, distinguish level-load palletizing from general reorientation. Four-axis palletizers can position and rotate a level product around the vertical axis, but cannot independently supply every pitch and roll angle. A six-axis arm may support tilted presentation or recovery, yet it must be assessed on the same pallet pattern and load. Check the lowest pickup, highest layer, farthest corner and safe exit path.
Precision and throughput: compare the same task
The comparison uses ±0.05 mm for ABB IRB 760 and ±0.5 mm for Kawasaki MX500N. These figures should be read in their documented configuration scope. Repeatability is not absolute accuracy, camera calibration accuracy or finished-part capability. Fixture variation, TCP calibration, thermal conditions and tool compliance can dominate the error at the process point, especially when the tool extends far from the flange.
Ask each integrator to execute the same representative path with the same payload model, tool length, process dwell and stop conditions. Report transfer time, settling time, process time and waiting time separately. Published standard cycles often use different loads and distances; dividing one catalogue cycle by another would not establish the production advantage of ABB IRB 760 over Kawasaki MX500N. Use a measured or validated application cycle before assigning a throughput benefit.
Programming, controls and production integration
ABB installations use the RAPID and RobotStudio engineering workflow, with the quoted controller and software determining the available functions. Kawasaki uses AS programming and K-ROSET for its documented simulation workflow. Existing staff skills, reusable code, spare parts and local service can therefore matter as much as the arm’s dimensional specifications.
Specify the PLC handshakes before ordering: cycle request, ready, busy, complete, fault, part present and recovery authorization. Define how an interrupted operation resumes without repeating a dangerous or quality-critical action. Vision, force sensing, fieldbus communication and external-axis coordination must be checked as explicit included or optional functions. An Ethernet connector does not by itself prove that a particular industrial protocol or software interface is licensed and supported.
Protection, installation and maintenance
Match the precise protection package to the process. Standard, protected, cleanroom, foundry and washing configurations can have different seals, services and maintenance requirements. Do not transfer the best optional IP or cleanroom rating to an unprotected base model. Check the controller location, cable bend radius, available lifting access and base reactions with the installer.
Plan for tooling changes and fault recovery as normal operating tasks. A gripper that can only be removed after dismantling guarding creates a maintenance cost that the robot purchase price will not show. Include access to connectors, lubrication points, mastering references and spare cables. Use a task-specific risk assessment and validated safeguarding for the whole installation; these industrial-arm specifications do not authorize unguarded collaborative operation.
Price and lifecycle value
The source reviews list From USD 90,000 for ABB IRB 760 and From USD 100,000 for Kawasaki MX500N. These are historical editorial starting references, not current sales offers, confirmed stock or matched quotations. Revision, supply condition and included controller can change the relevant price. Request a written quotation naming the arm, controller, pendant, cables, software options, warranty and commissioning scope.
Compare the installed production scope: tool, fixtures, sensing, guarding, machine interface, programming, acceptance and training. For palletizing, include infeed control, pallet detection, load retention and gripper services. Keep purchase cost and recurring support costs separate. No payback figure is defensible until the actual cycle, yield, utilization and installation quotation are known.
Selection and acceptance plan
Decision gate | ABB IRB 760 | Kawasaki MX500N |
|---|---|---|
Strongest documented fit | level-load palletizing with the specified ABB payload | heavy-load reorientation using a six-axis wrist |
Main boundary | Tool mass, wrist moments and access constrain the headline specification. | Confirm exact configuration, controller, wrist loading and installation envelope. |
Required approval | Exact ABB variant, tool load and validated process path | Exact competitor revision, tool load and validated process path |
Acceptance evidence | Agreed parts, path, quality and recovery results | The same agreed parts, path, quality and recovery results |
Advance ABB IRB 760 when level-load palletizing with the specified ABB payload solves the real constraint and its selected configuration passes the load and access checks. Advance Kawasaki MX500N when heavy-load reorientation using a six-axis wrist provides the more suitable process arrangement. Reject either candidate if a mandatory pose, protection requirement or controller function cannot be demonstrated. A purchasing shortlist should preserve these conditions instead of converting a single catalogue advantage into a blanket recommendation.
Before acceptance, agree the representative parts, tool states, operating sequence and quality criteria with both suppliers. Demonstrate cold start, normal production, rejected parts, interrupted cycles and controlled recovery. Record the final tool data and software backup. This turns the comparison into a repeatable purchasing decision and helps prevent a later fixture change from invalidating the original robot selection.
Frequently asked questions
Which robot is better for this application?
ABB IRB 760 is the stronger starting point for level-load palletizing with the specified ABB payload, while Kawasaki MX500N is worth shortlisting for heavy-load reorientation using a six-axis wrist. The final choice depends on the real loaded path, required protection, controls and acceptance results. Neither a higher payload nor a longer reach establishes a universal winner.
What payload should I use for the comparison?
Use 450 kg for the specified ABB IRB 760 example and 500 kg for Kawasaki MX500N, subject to all documented load and orientation conditions. Include the tool, adapters, sensors and carried part. Confirm exact configuration, controller, wrist loading and installation envelope.
Does the stated reach guarantee access to my fixture?
No. The comparison gives 3180 mm for ABB IRB 760 and 2540 mm for Kawasaki MX500N using the stated model references. Joint limits, reach reference points, wrist orientation, tool length and collisions determine whether the actual fixture is accessible. Simulate the full approach and exit path.
Can I use the best specifications from every family variant?
No. Keep each named model and revision intact. A different arm length, controller generation or protection option can change the relevant specification. Do not combine one version’s maximum payload with another version’s maximum reach.
Is repeatability the same as finished-part accuracy?
No. The stated values are ±0.05 mm for the ABB scope and ±0.5 mm for the competitor scope. Finished-part results also depend on fixtures, TCP calibration, sensing, thermal conditions and tool compliance. Validate the actual process instead of treating catalogue repeatability as a complete accuracy guarantee.
Are the review starting prices current purchase quotations?
No. From USD 90,000 and From USD 100,000 are historical references from the linked ATC reviews. They are not current matched offers and do not establish stock or the installed-cell cost. Obtain configuration-specific quotations with the controller, software, tooling, safety and commissioning scope itemized.
Can these robots operate safely next to people without guarding?
These specifications do not establish a safe unguarded installation. Assess the complete task, tool, load and machine interface, then implement and validate the required safeguarding and operating procedures. Do not infer collaborative operation from a compact arm, limited payload or education setting.
What should an acceptance test compare?
Use the same parts, actual tool load, fixture locations, path and quality criteria for ABB IRB 760 and Kawasaki MX500N. Check production timing, settling, interruptions and recovery. Include the highest layer and farthest pallet corner. Approve the exact delivered configuration and preserve its final settings.
Related ATC reviews
Specifications describe the model scope identified above. Prices are indicative historical review references and may change. Confirm current manufacturer documentation, local supply, controller compatibility and the exact configuration before purchase.


